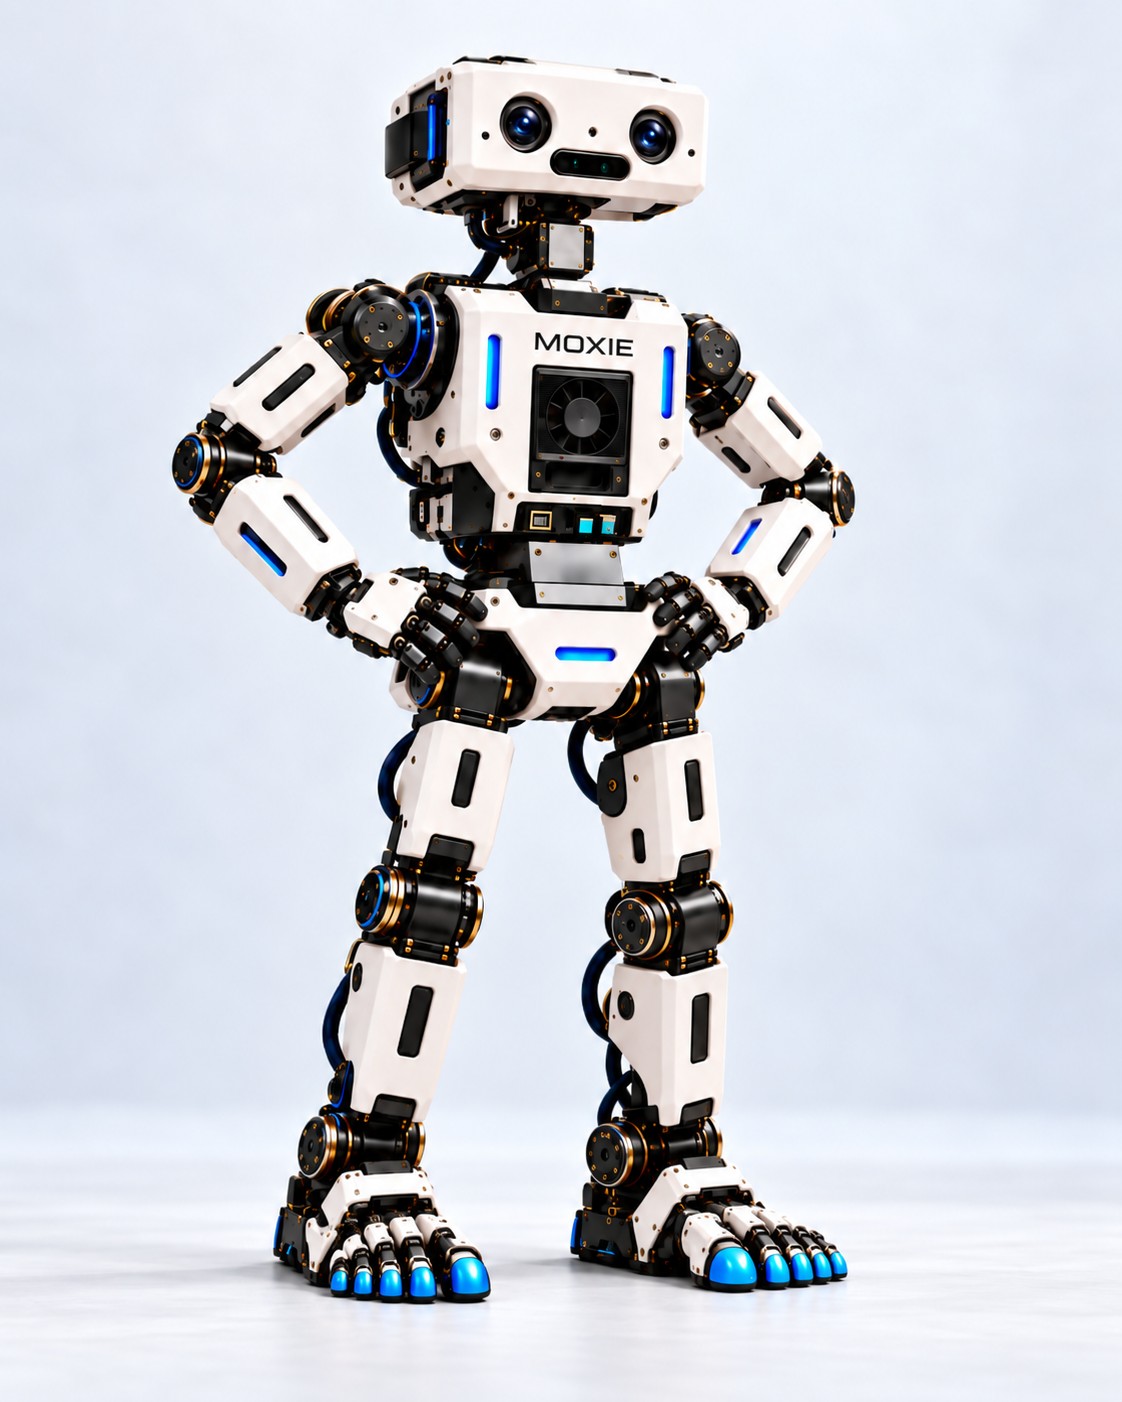
Open-source robot · Apache-2.0
MOXIE
610 mm Adaptive-Foot Humanoid Robot
MOXIE is a roughly two-foot-tall research humanoid built to walk indoors, handle modestly rough ground, see and talk locally, and act as a fully programmable embodied-AI platform. It's named for the super-robot Moxie in Arthur C. Clarke and Gentry Lee's Rama Revealed.
The core idea: separate thinking from balancing. The Jetson reasons, while a dedicated microcontroller keeps the robot upright. Hands use five visible fingers driven by three motor groups, so MOXIE can point, pinch, and grip without the weight of a motor per finger.
v3.9 · 27 Sep 2026 · 76 pages
About the document
The MOXIE Concept Design, Procurement List, and Assembly Guide is a complete, buildable blueprint. It covers design goals, mechanical and electrical architecture, sensor and actuator choices, a full parts list, and assembly steps — everything needed to build a MOXIE of your own.
- ▸ Concept design and executive summary
- ▸ Mechanical blueprint sheet and joint layout
- ▸ Electrical architecture and circuit diagram
- ▸ Full procurement list / bill of materials
- ▸ Step-by-step assembly guide
- ▸ Apache-2.0 license text and repository guidance
Engineering concept: dimensions, loads and thermal margins are to be validated in prototype testing. Renders are illustrative; the written tables and parts list are authoritative.
Baseline specs
- Height
- 600–620 mm
- Target mass
- 5.5–6.5 kg
- Powered joints
- 32 (20 body · 6 toe groups · 6 hand groups)
- Legs
- 6 DOF each
- Arms & hands
- 3 DOF arms · 5-finger tendon-driven hands
- Feet
- 5 compliant toes per foot, mirrored left/right
- Compute
- Jetson Orin NX Super 8GB · Ubuntu + ROS2
- Balance controller
- Teensy 4.1 running a 200–500 Hz gait loop
- Perception
- Stereo IMX219 cameras · ToF depth · mic array
- Power
- Milwaukee M18 XC8.0 (~144 Wh), hot-swappable